

How Does GPS Determine Your Location?
The blue dot on your map is not magic and not triangulation with cell towers alone. Global Positioning System receivers listen to precisely timed radio signals from satellites, infer distances from nanosecond-scale delays, and solve a geometry problem on a sphere. Maps, Wi‑Fi assists, and barometers can refine the experience, but the core fix is time plus trilateration.
8 min read · Updated 2026-10-04
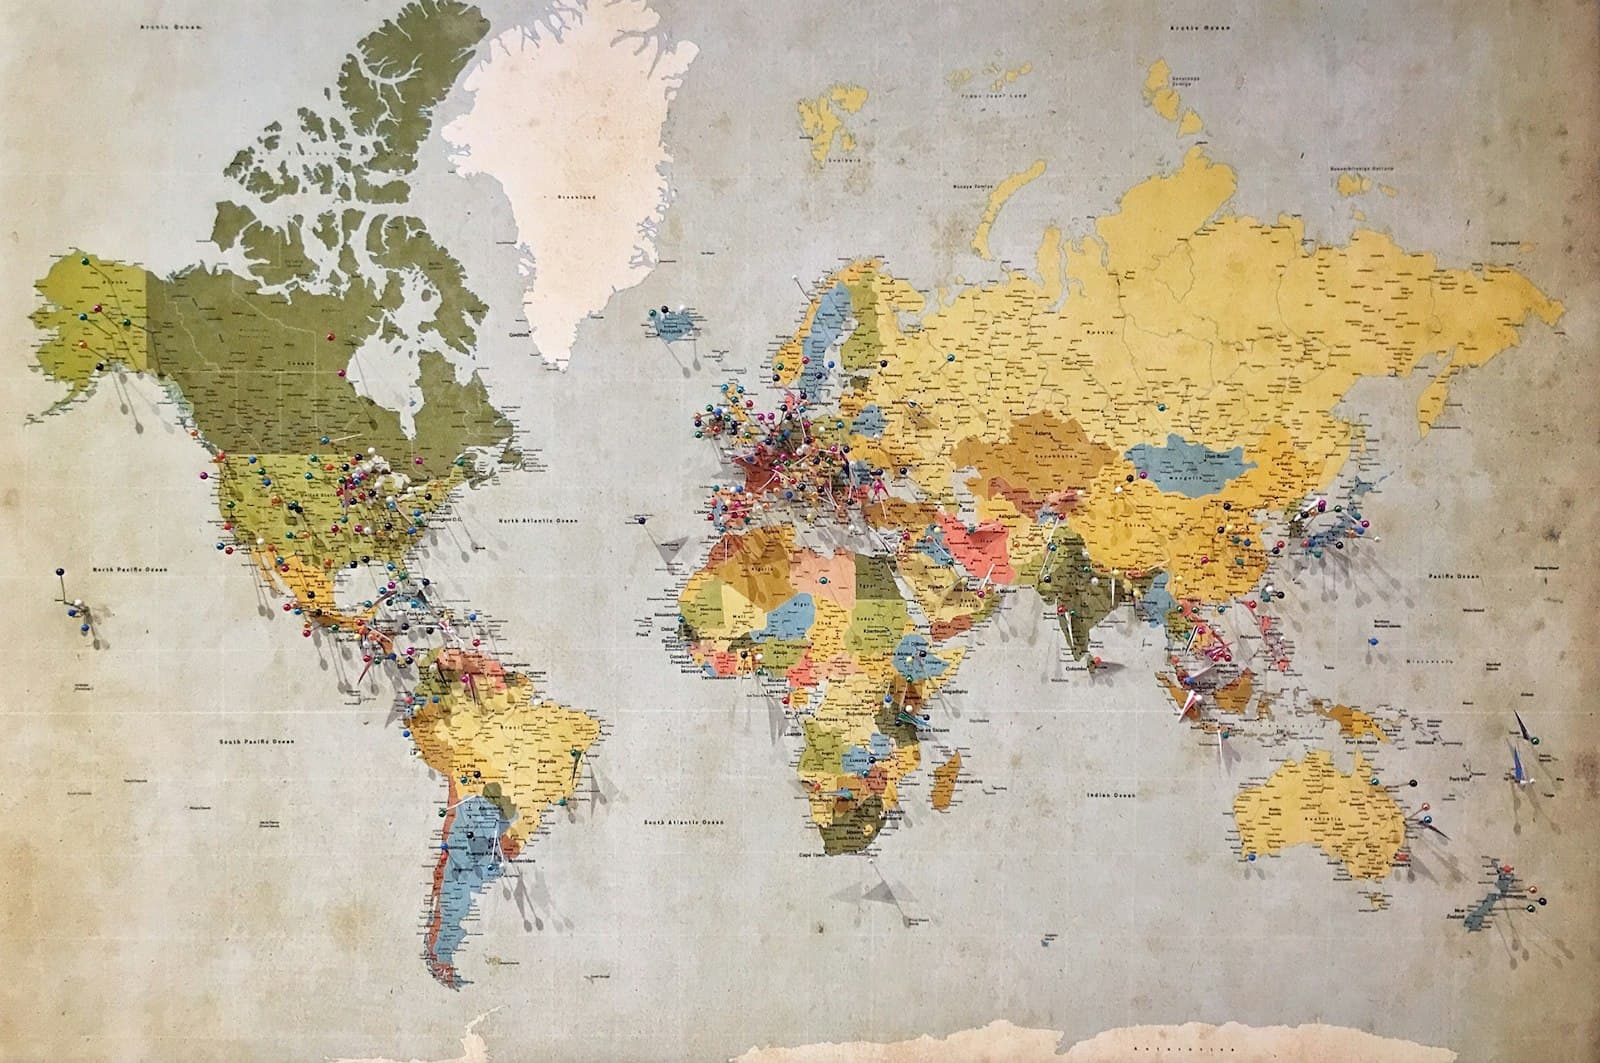
Quick answer
Each GPS satellite broadcasts its identity, a precise time from an onboard atomic clock, and data describing its orbit. Your receiver compares the time encoded in the signal with the time it received the signal. Radio waves travel at the speed of light, so a measured delay converts to a distance from that satellite. One distance defines a sphere around the satellite; two spheres intersect in a circle; three narrow that circle to two points; a fourth measurement—or knowledge that you are on Earth’s surface—picks the correct point and calibrates the receiver’s imperfect clock.
Civilian GPS is engineered for roughly meter-level horizontal accuracy under open sky in good conditions. Urban canyons, tree cover, indoor use, and atmospheric delays can degrade or block fixes. Assisted GPS (A-GPS) speeds acquisition by supplying approximate time, position, and satellite almanac from the network, but the fundamental ranging idea remains timing-based trilateration.
The constellation and what it broadcasts
The U.S. Global Positioning System is a constellation of satellites in medium Earth orbit, arranged so that a receiver with a clear view of the sky can typically track several satellites at once. Other global and regional systems—such as Europe’s Galileo, Russia’s GLONASS, and China’s BeiDou—use the same broad principle: synchronized clocks in space and ranging codes on radio carriers.
Each satellite continuously transmits navigation messages: clock corrections, ephemeris (precise orbit parameters for that satellite), and almanac (coarser orbit data for the whole constellation). Receivers use these messages to compute where each satellite was at the instant the signal was transmitted, which is essential because the satellites move at thousands of meters per second.
Atomic clocks and why timing matters
GPS ranging treats time as distance. Light and radio signals travel about 299,792,458 meters per second in vacuum. An error of one microsecond in timing would translate to roughly 300 meters of range error—unacceptable for navigation. Satellite clocks are therefore atomic frequency standards, steered and monitored by ground control so users can predict satellite time to high precision.
Your phone’s quartz clock is not atomic. Receivers solve for an extra unknown: the bias between receiver time and GPS system time. That is why you need a fourth satellite (or an external constraint) in addition to the three required for three-dimensional position: three satellites give three ranges plus an unknown clock, four equations for four unknowns (x, y, z, and clock bias).
Distances in navigation are often given in meters; aviation and maritime charts may mix nautical miles or feet. Converting length units consistently matters when you compare GPS error budgets (meters) with runway elevations (feet) or survey notes.
From timestamp to distance
Signals carry repeating digital codes. A receiver shifts its local copy of the code until it aligns with the incoming signal; the shift is proportional to travel time. Modern receivers also measure carrier phase for high-precision surveying, but consumer devices rely primarily on code-based pseudoranges for fixes.
The word pseudorange is honest: the raw measurement includes clock errors, atmospheric delay, multipath, and noise. Receivers and augmentation systems apply models and filters to estimate a true geometric range, but “a few meters” of civilian uncertainty is the normal cost of doing this in real environments rather than in a textbook vacuum.
Trilateration, not triangulation
Triangulation finds direction from angles. GPS finds distance from time delay. Each satellite defines a sphere centered on the satellite with radius equal to the measured range. Your position must lie on that sphere. Two satellites give two spheres whose intersection is generally a circle; a third satellite cuts that circle to two symmetric points; Earth’s surface or a fourth range disambiguates.
Satellite A
Measure delay → distance r_A → receiver lies on sphere centered at A with radius r_A.
Satellite B
Second sphere intersects the first in a circle of possible locations.
Satellite C
Third sphere cuts the circle to two points (mirror images in geometry).
Satellite D (or surface)
Fourth range fixes clock bias; Earth model rejects the point in space.
Fix
Least-squares solvers refine position using many satellites and weights.
Each range is a sphere; intersections narrow the possible receiver location.
In practice receivers track more than four satellites and compute a least-squares or Kalman-filter solution that averages noise and flags outliers. Dilution of precision (DOP) summarizes how satellite geometry spreads numerical error: tight clusters of satellites low on the horizon produce worse horizontal fixes than satellites spread across the sky.
Atmosphere, ionosphere, and multipath
Signals slow slightly in the neutral atmosphere and refract in the ionosphere, changing effective path length by meters unless corrected. Broadcast models and dual-frequency receivers reduce those errors; single-frequency phones rely on corrected models and smoothing.
Multipath is the echo problem: signals reflect off buildings, vehicles, or ground before reaching the antenna, making the path look longer than the true line-of-sight range. Urban canyons are multipath factories, which is why the same phone can report a jump of several meters when you walk past a glass facade.
Everyday accuracy factors
| Factor | Typical effect |
|---|---|
| Open sky, good geometry | Often near civilian design goals (~meters horizontal) |
| Urban canyons | Large jumps, inflated error estimates, lost fixes |
| Heavy tree cover | Weaker signals, more noise and multipath |
| Indoor / underground | Signal blocked; GPS alone often fails |
| Ionospheric disturbance | Extra range error until models catch up |
| Cold start without assist | Longer time to first fix while searching sky |
Assisted GPS (A-GPS)
A-GPS downloads approximate location, time, and satellite visibility from cellular or Wi‑Fi networks. That shrinks the search space so the receiver can lock onto signals in seconds instead of minutes after power-on. Assistance does not replace satellite ranging for the final fix unless the device falls back to purely network-based location when GPS signals are unavailable—then accuracy can drop to cell-tower or Wi‑Fi fingerprint scales (tens to hundreds of meters).
Accuracy limits and what “GPS” on your phone means
Official GPS performance documents describe expected ranges for civilian service, which include intentional design limits historically discussed in policy contexts and natural error sources. Survey-grade equipment with differential corrections achieves centimeters; a hiking watch in a forest does not. Vertical accuracy is usually worse than horizontal because satellite geometry is poor for up-down separation.
Modern phones fuse GPS with accelerometers, gyroscopes, magnetometers, barometers, and Wi‑Fi/cell fixes. The label “GPS” in the status bar means satellite ranging contributed; fused maps may still drift in parking garages where only inertial and network guesses remain.
Indoors, jamming, and spoofing
Roofs and walls attenuate microwave signals from space; a receiver may see no usable satellites or only reflected fragments. That is why turn-by-turn navigation often switches to dead reckoning or last-known fixes until you exit the building. Specialized indoor positioning uses Bluetooth beacons, ultra-wideband, or Wi‑Fi fingerprints—different physics from GPS trilateration.
Intentional jamming overwhelms the receiver with noise; spoofing broadcasts fake signals to shift apparent position. Civil aviation and critical infrastructure study these threats; consumer users mostly encounter accidental multipath and weak signal rather than attack. Understanding the honest error budget helps you interpret why a dot on a map sometimes lags reality by a lane width or more.
Try it yourself
GPS ephemerides and error budgets are published in meters per second and meters. If you are reading a spec sheet in feet or converting runway visibility units, a length converter keeps comparisons honest when you sanity-check how far off a consumer fix might be relative to a feature on the ground.
- Length Converter — switch between meters, feet, kilometers, and miles when interpreting GPS accuracy statements or map scales.
The guide on metric versus imperial units pairs well with navigation habits: aviation still mixes nm and feet while phone APIs often report decimal degrees and meters internally.
Further reading
Official and technical sources
- GPS.gov — The Global Positioning System
- GPS.gov — GPS accuracy
- NOAA National Geodetic Survey — GPS — Survey-oriented overview from NOAA.
- NASA — Global Positioning System
- European Space Agency — Galileo — Independent GNSS with compatible ranging principles.
Related articles
Science
Why Does the Sky Look Blue?
Sunlight, wavelengths, Rayleigh scattering, and why sunsets turn red—plus clouds, haze, and common myths.
7 min read · 2026-10-04
Read the article
Technology
What Happens When You Enter a URL?
A step-by-step path from keypress to first paint, including DNS, TLS, redirects, and caching.
8 min read · 2026-10-04
Read the article
Science
Why Does the Human Brain Need Sleep?
Circadian timing, sleep pressure, memory and attention, REM and non-REM—and what researchers still do not know.
7 min read · 2026-10-04
Read the article